> For the complete documentation index, see [llms.txt](https://docs.arkelectron.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.arkelectron.com/products/flight-controller/ark-pixhawk-autopilot-bus-carrier/hardware.md).
# Hardware Reference
ARK Pixhawk Autopilot Bus Carrier
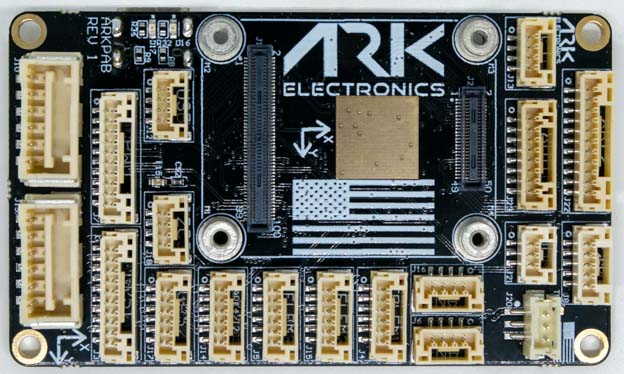
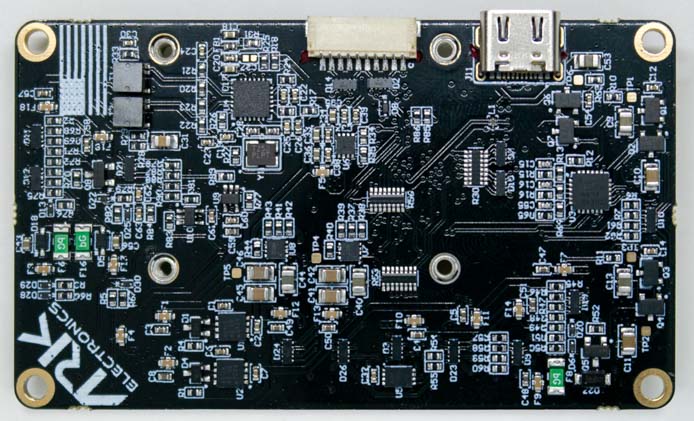
## Specifications
| Specification | Value |
| ---------------------------- | --------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------- |
| Form factor | [Pixhawk Autopilot Bus (PAB)](https://github.com/pixhawk/Pixhawk-Standards/blob/master/DS-010%20Pixhawk%20Autopilot%20Bus%20Standard.pdf?_ga=2.20605755.2081055420.1671562222-391294592.1671562222) |
| PAB board-to-board interface | 100-pin Hirose DF40, 50-pin Hirose DF40 ([Pixhawk Autopilot Bus](https://github.com/pixhawk/Pixhawk-Standards/blob/master/DS-010%20Pixhawk%20Autopilot%20Bus%20Standard.pdf)) |
| Power module inputs | Dual digital power module inputs: 5 V input, I2C power monitor, 6-pin Molex CLIK-Mate |
| Ethernet | 100 Mbps, built-in magnetics, 4-pin JST-GH |
| GPS | Full GPS plus safety switch port, 10-pin JST-GH. Basic GPS port, 6-pin JST-GH |
| CAN | Dual CAN ports, 4-pin JST-GH |
| Telemetry | Triple telemetry ports with flow control, 6-pin JST-GH |
| PWM | Eight PWM outputs, 10-pin JST-GH |
| UART/I2C | 6-pin JST-GH |
| I2C | 4-pin JST-GH |
| RC | PPM RC port, 3-pin JST-GH. DSM RC port, 3-pin JST-ZH |
| SPI | 11-pin JST-GH |
| ADIO | 8-pin JST-GH |
| Debug | 10-pin JST-SH |
| Power | 5 V |
| Dimensions | 74.0 × 43.5 × 12.0 mm, without flight controller module |
| Weight | 22 g, without flight controller module |
## Pinout
See the [Pinout](/products/flight-controller/ark-pixhawk-autopilot-bus-carrier/hardware/pinout.md) page for the connector pinouts.
{% content-ref url="/pages/8FoCumpSHonz9iz7bpP3" %}
[Pinout](/products/flight-controller/ark-pixhawk-autopilot-bus-carrier/hardware/pinout.md)
{% endcontent-ref %}
## LEDs
There are two LEDs on the ARK PAB:
| LED | Meaning |
| ----- | ----------------- |
| Red | Ethernet power |
| Green | Ethernet activity |
## Power
* 5V input on `POWER1`, `POWER2`, `USB C`, and the `USB JST-GH` connector
* Input is prioritized in the following order: POWER1 > POWER2 > USB. Only the selected input powers the board; see [Carrier Power Inputs](/knowledge-base/knowledge-base/carrier-power-inputs.md)
* `USB C` and the `USB JST-GH` are in parallel
* Overvoltage protection at 5.85V
* Undervoltage protection at 3.81V
* `VDD_5V_HIPOWER` and `VDD_5V_PERIPH` can each provide a total of 1.5A across all the connectors
## 3D Model and Case
| File | Contents |
| ------------------------------------------------------------------------------------------------------------------------------------------------- | ------------------------------------------------ |
| [ARK\_PAB\_Carrier\_3D\_Model.step](https://github.com/ARK-Electronics/ark-hardware/raw/main/ARK_PAB_Carrier/model/ARK_PAB_Carrier_3D_Model.step) | Board |
| [ARK\_PAB\_Carrier\_3D\_PDF.pdf](https://github.com/ARK-Electronics/ark-hardware/raw/main/ARK_PAB_Carrier/model/ARK_PAB_Carrier_3D_PDF.pdf) | Board, 3D PDF |
| [Top\_Case.stl](https://github.com/ARK-Electronics/ark-hardware/raw/main/ARK_PAB_Carrier/case/Top_Case.stl) | Case top |
| [Bottom\_Case.stl](https://github.com/ARK-Electronics/ark-hardware/raw/main/ARK_PAB_Carrier/case/Bottom_Case.stl) | Case bottom |
| [Som\_Case.stl](https://github.com/ARK-Electronics/ark-hardware/raw/main/ARK_PAB_Carrier/case/Som_Case.stl) | Case part for the flight controller module (SOM) |
All files: [ARK\_PAB\_Carrier in ark-hardware](https://github.com/ARK-Electronics/ark-hardware/tree/main/ARK_PAB_Carrier)
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.arkelectron.com/products/flight-controller/ark-pixhawk-autopilot-bus-carrier/hardware.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.
